Skip to content

robotics

Going through the AI for Industry Challenge
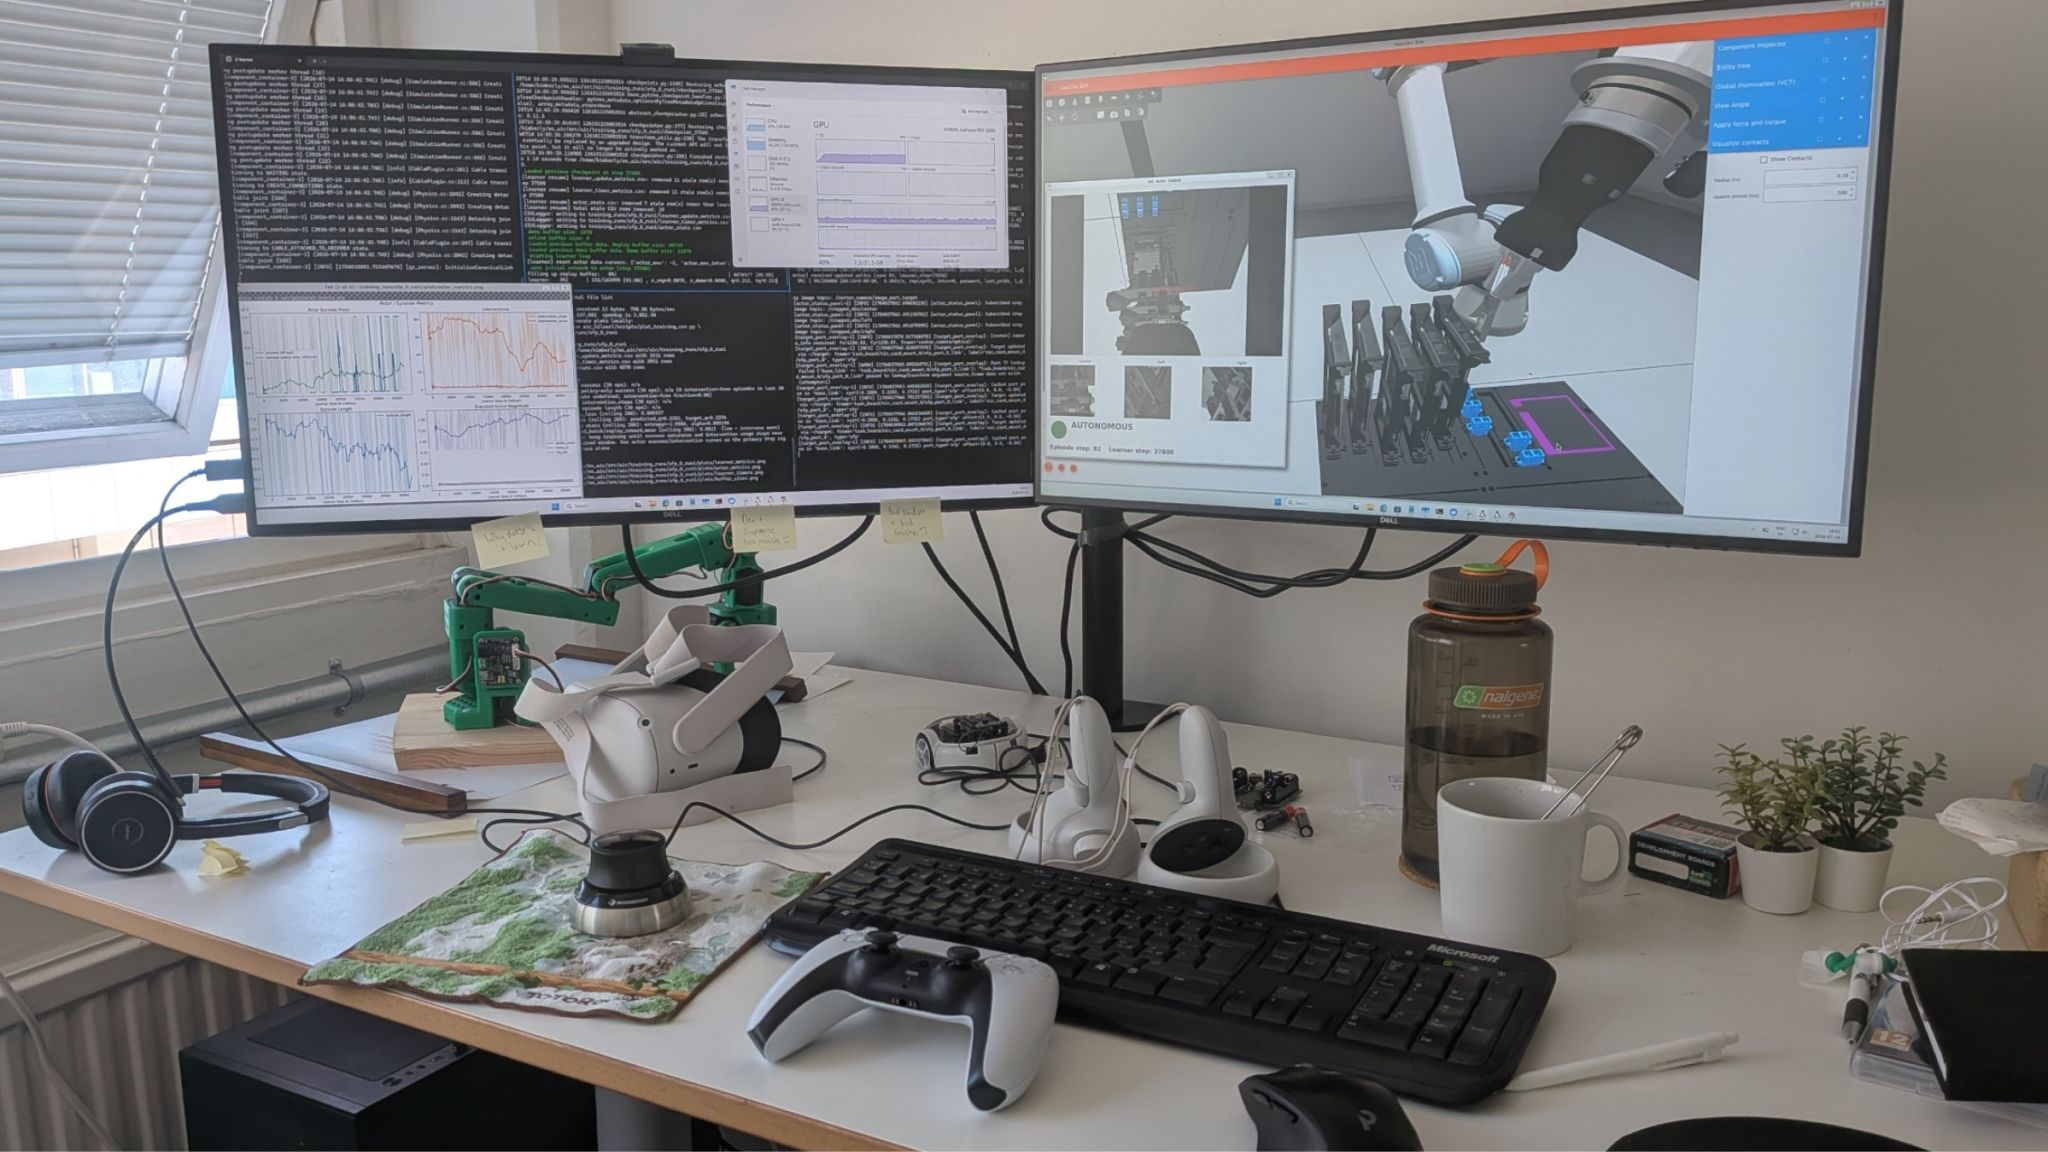
My very first official assignment with McGuire Robotics AB was joining team b-robotized in the AI for Industry Challenge, an open competition by Intrinsic about automating electronics assembly with a robot arm. In this post I'll go through how we detected the task board with ROS 2 and some good old OpenCV, how I ended up as a robot arm tamer with a PlayStation controller, and what we took away from it once we didn't make it into the next phase.

Robot arm!

It is always good to be reminded of how hard robotics can be! I got a taste of that again when I worked with the SO-100 this summer and the last few months. But I had a lot of fun building it at least!

ROS 2: Across the Windows-Verse

image

Three months ago, I went head-first into full-on Windows Development. Have I gone screaming mad already? Well... no, actually! I managed to establish a handy workflow between the ROS native Windows install and WSL2. This blog post shows the process of what I've set up.

Enjoy!

image

In this blog post, I explain how I tried to figure out in which simulator I should invest some of my project development time. Little did I know of the very deep rabbit hole that presented itself, and I dived right in! Did it help me with my choice? A little, but perhaps I've created something that is even more useful: a best-of-list of robot simulators.

Enjoy!

Robotics on Windows, Are You Mad?!

Yes, I am a little bit mad. Why the hell do I torture myself to get development to work on Windows... well, I tried to trace back the journey for robotics development, where I desperately tried to hang on to Windows, but had to settle for a dual boot, only to slowly return to give development on Windows a chance again.

Enjoy! (I hope 😉)